🇨🇳 EngineAI SE01
Watch changes · Evidence history · Cited research export · Plan a pilot
Score breakdown
Each pillar is scored 0–100 from published specs, then weighted into the HMX. Compare it only with other humanoid robots — each category uses its own reference scales. See the full methodology →
Notable
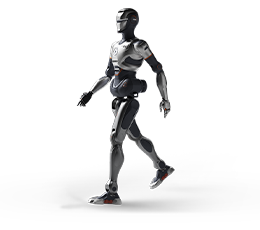
EngineAI's ~170 cm full-size flagship, noted for a bio-inspired natural walking gait via self-developed harmonic joints and learning-based control. Specs vary by source (some list 180 cm / 80 kg / 12 leg-DOF); the 170 cm / 55 kg / 32-DOF figures recur most across independent listings.
Specifications
Evidence is attached to each value. Robot-wide source links do not verify every field. A source about an older value cannot support the current specification.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
EngineAI SE01 in context: rank, rivals and specs
Compare with Kawada NEXTAGE Fillie →SE01 is a humanoid robot from EngineAI in China, and it is at the prototype stage. It scores 37.6 on the Humanoid Metric, ranking 121st of 156.
On the leaderboard it sits between Kawada NEXTAGE Fillie (HMX 38.1) and AgiBot G2 Air (HMX 37.1).
Against the 156 humanoid robots ranked, its clearest strength is mobility & locomotion (62.0 against a median of 34.8) and its clearest weakness is autonomy & intelligence (20.0 against 70.0).
Its published price of $20,000 is below 64% of the 55 other humanoid robots with a public price.
On autonomy, it has demonstrated autonomy only in research settings. No deployment is on record.
Its specifications carry a medium-confidence grade from 3 cited sources, as of 2026-06.
Task evidence
Task capability is not inferred from hardware specifications or general autonomy labels. Find robots for a task →
No task-specific evidence recorded. Capability remains unknown.
Sources · robot-level references, as of 2026-06
- https://www.robotsinternational.com/EngineAI-SE01-Humanoid-Robot.htm
- https://humanoid.guide/product/se01/
- https://www.therobotreport.com/engineai-releases-pm01-humanoid-robot-for-commercial-educational-use/
Machine-readable: HIS Layer 0 manifest · what's this?
Frequently asked questions about the EngineAI SE01
How much does the EngineAI SE01 cost?
The EngineAI SE01 has a published price of $20,000.
What are the EngineAI SE01's specs?
Published specifications: speed 2 m/s, runtime 2 h, degrees of freedom 32, degrees of freedom per hand 6, height 170 cm, weight 55 kg. Not published: payload.
Is the EngineAI SE01 autonomous?
The EngineAI SE01 has demonstrated autonomy only in research settings. The grade reflects demonstrations, not marketing claims.
How does the EngineAI SE01 compare to the Kawada NEXTAGE Fillie?
On the HMX, the EngineAI SE01 scores 37.6 and the Kawada NEXTAGE Fillie 38.1. The EngineAI SE01 leads on manipulation & dexterity, mobility & locomotion, hardware & engineering and ecosystem & viability; the Kawada NEXTAGE Fillie leads on autonomy & intelligence and commercial readiness & deployment.
Who makes the EngineAI SE01?
The EngineAI SE01 is made by EngineAI, in China.
Embed this score
