JAXA Kibo mock-up module
unknown · unverified
- No deployment-specific evidence recorded.
Watch changes · Evidence history and cited research export (API access) · Plan a pilot
Each pillar is scored 0–100 from published specs, then weighted into the HMX. Compare it only with other humanoid robots — each category uses its own reference scales. See the full methodology →
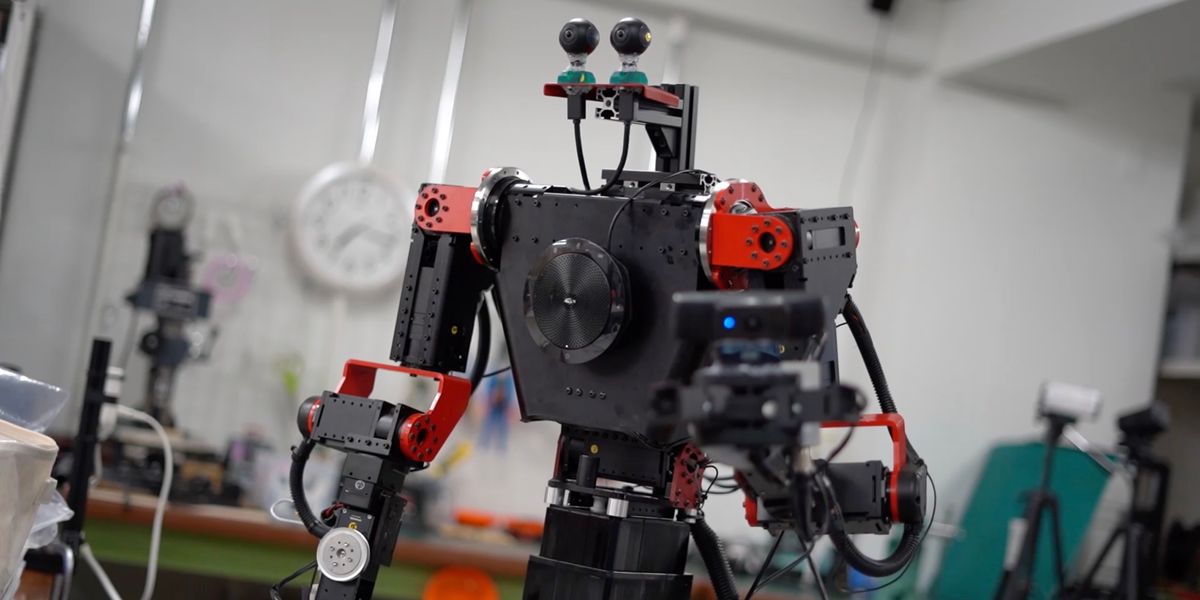
Space-dedicated humanoid torso (no legs) meant to do astronaut-substitute work on space stations and lunar bases.
Legacy mentions are unverified. A partnership or announcement is not proof of an active deployment. Evidence labels do not change HMX v2 scoring.
JAXA Kibo mock-up module
unknown · unverified
Simulated lunar environments
unknown · unverified
ISS technology demonstrations
unknown · unverified
JAXA joint research agreement
unknown · unverified
Evidence is attached to each value. Robot-wide source links do not verify every field. A source about an older value cannot support the current specification.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
G1 is a humanoid robot from GITAI in Japan, and it is at the prototype stage. It scores 33.9 on the Humanoid Metric, ranking 134th of 169.
On the leaderboard it sits between RobotEra M7 (HMX 34.6) and PAL Robotics TALOS (HMX 33.9).
Against the 169 humanoid robots ranked, its clearest strength is manipulation & dexterity (50.0 against a median of 40.0) and its clearest weakness is autonomy & intelligence (35.0 against 70.0).
By the published specifications, it is taller than 99% of the 138 other humanoid robots publishing a height (200 cm), is heavier than 93% of the 125 other humanoid robots publishing a weight (120 kg) and has fewer degrees of freedom than 83% of the 132 other humanoid robots publishing a degree-of-freedom count (21).
On autonomy, it is remotely operated in its public demonstrations, which the index caps low however capable the hardware. 4 deployment claims are on record, none yet backed by a customer, the press or the vendor.
Its specifications carry a medium-confidence grade from 3 cited sources, as of 2026-07.
Task capability is not inferred from hardware specifications or general autonomy labels. Find robots for a task →
No task-specific evidence recorded. Capability remains unknown.
Machine-readable: HIS Layer 0 manifest at /robot/gitai-g1/manifest.json, with a free API key · what's this?
GITAI has not published a price for the GITAI G1, and none is estimated here.
Published specifications: degrees of freedom 21, degrees of freedom per hand 8, height 200 cm, weight 120 kg. Not published: payload, speed and runtime.
The GITAI G1 is remotely operated in its public demonstrations, which the index caps low however capable the hardware. The grade reflects demonstrations, not marketing claims.
On the HMX, the GITAI G1 scores 33.9 and the RobotEra M7 34.6. The GITAI G1 leads on commercial readiness & deployment; the RobotEra M7 leads on manipulation & dexterity, hardware & engineering and ecosystem & viability.
The GITAI G1 is made by GITAI, in Japan.

Nothing is deleted: every version of this record is kept, with what changed in each.