Each pillar is scored 0–100 from published specs, then weighted into the
HMX. Compare it only with other
humanoid robots —
each category uses its own reference scales.
See the full methodology →
Notable
Successor to IIT's iCub research platform for ergonomic human-robot collaboration in industry; spun off a commercial venture, Generative Bionics, in 2024.
Deployment evidence
Legacy mentions are unverified. A partnership or announcement is not proof of an active deployment. Evidence labels do not change HMX v2 scoring.
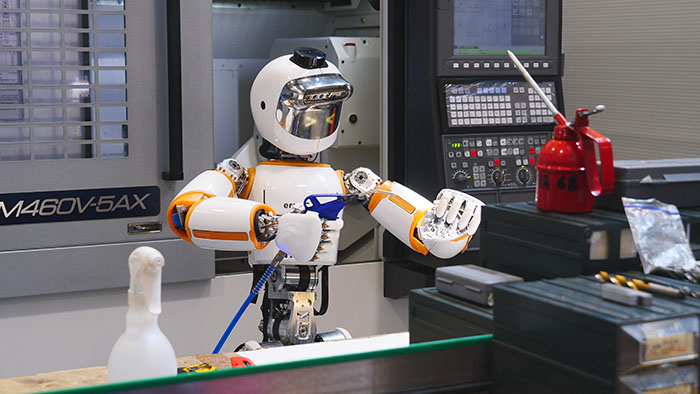
Collaborative industrial humanoid developed jointly by IIT and INAIL to reduce physical risk and prevent musculoskeletal injuries in manufacturing and logistics.
Specifications
Evidence is attached to each value. Robot-wide source links do not verify every field. A source about an older value cannot support the current specification.
Height
150.0 cm
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Weight
55.7 kg
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Payload
10.0 kg
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Travel speed
Undisclosed
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Runtime
Undisclosed
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Battery
Undisclosed
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Total DoF
54 DoF
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Hand DoF per hand
9 DoF
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Dexterous hands
Yes
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Actuation
electric
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Form factor
bipedal
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Onboard compute
Multi-core embedded x86/ARM system (Rockchip RK3588 edge accelerator) running Linux and YARP/ROS middleware
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
ergoCub is a humanoid robot from Istituto Italiano di Tecnologia in Italy, and it is a research platform. It scores 43.1 on the Humanoid Metric, ranking 100th of 169.
On the leaderboard it sits between Booster K2 (HMX 43.2) and KIT High Performance Humanoid Technologies Lab ARMAR-DE (HMX 42.8).
Against the 169 humanoid robots ranked, its clearest strength is hardware & engineering (81.2 against a median of 56.9) and its clearest weakness is commercial readiness & deployment (15.0 against 67.0).
By the published specifications, it has more degrees of freedom than 85% of the 132 other humanoid robots publishing a degree-of-freedom count (54).
On autonomy, it has demonstrated autonomy under human supervision, not unsupervised work. It has 1 deployment with evidence (1 vendor claimed).
Its specifications carry a medium-confidence grade from 3 cited sources, as of 2026-07.
Task evidence
Task capability is not inferred from hardware specifications or general autonomy labels. Find robots for a task →
No task-specific evidence recorded. Capability remains unknown.
Machine-readable: HIS Layer 0 manifest at /robot/iit-ergocub/manifest.json, with a free API key · what's this?
Frequently asked questions about the Istituto Italiano di Tecnologia ergoCub
How much does the Istituto Italiano di Tecnologia ergoCub cost?
Istituto Italiano di Tecnologia has not published a price for the Istituto Italiano di Tecnologia ergoCub, and none is estimated here.
What are the Istituto Italiano di Tecnologia ergoCub's specs?
Published specifications: payload 10 kg, degrees of freedom 54, degrees of freedom per hand 9, height 150 cm, weight 55.7 kg. Not published: speed and runtime.
Is the Istituto Italiano di Tecnologia ergoCub autonomous?
The Istituto Italiano di Tecnologia ergoCub has demonstrated autonomy under human supervision, not unsupervised work. The grade reflects demonstrations, not marketing claims.
How does the Istituto Italiano di Tecnologia ergoCub compare to the Booster K2?
On the HMX, the Istituto Italiano di Tecnologia ergoCub scores 43.1 and the Booster K2 43.2. The Istituto Italiano di Tecnologia ergoCub leads on manipulation & dexterity and hardware & engineering; the Booster K2 leads on autonomy & intelligence and commercial readiness & deployment.
Who makes the Istituto Italiano di Tecnologia ergoCub?
The Istituto Italiano di Tecnologia ergoCub is made by Istituto Italiano di Tecnologia, in Italy.
Nothing is deleted: every version of this record is kept, with what changed in each.
Version 354· 15 Sep 2026, 04:49 UTC· score then 43.1
ai model:
Human-aware whole-body control / ergonomic optimization research stack → Shared Embodied Intelligence framework combining vision-based intention recognition, biomechanical load estimation, and whole-body MPC
autonomy level:
research → supervised-autonomy
deployments:
entries edited
hand dof per hand:
— → 9
onboard compute:
NVIDIA Jetson AGX Xavier + Intel 11th-gen i7 → Multi-core embedded x86/ARM system (Rockchip RK3588 edge accelerator) running Linux and YARP/ROS middleware
Changed by a direct correction or a scoring update, not a research proposal.
Version 265· 15 Sep 2026, 04:28 UTC· score then 32.7
No field changed; the score was recalculated.
Changed by: Update ergoCub (reviewer)
First recorded version· 6 Sep 2026, 05:24 UTC· score then 32.7
The record as it stood when full copies began to be kept.
Data confidence: medium. Some figures for this robot rest on single or conflicting sources, or on manufacturer/aggregator material rather than independent reporting. Treat second-order specs as approximate. Fields marked “—” were genuinely undisclosed and left blank rather than estimated.