Kawasaki KAWARUBA hub
evaluation · vendor-claimed
- vendor source
Demonstrations and pilot test setups at Future Lab HANEDA, KAWARUBA innovation lab
Watch changes · Evidence history and cited research export (API access) · Plan a pilot
Each pillar is scored 0–100 from published specs, then weighted into the HMX. Compare it only with other humanoid robots — each category uses its own reference scales. See the full methodology →
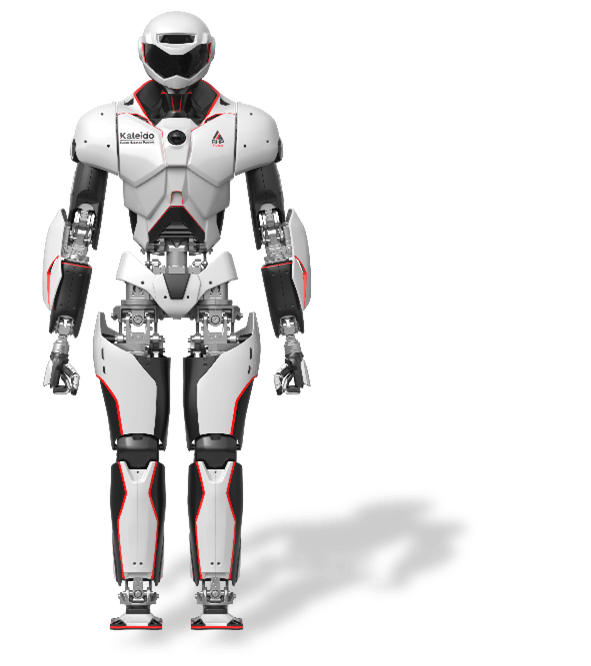
Ninth-generation Kaleido unveiled at iREX 2025 with reinforced waist/leg joints, a modular end-effector system, and LiDAR plus stereo cameras for SLAM-based navigation. It lifts up to ~18 kg and supports hybrid operation (autonomous walking with VR-headset remote control), aimed at a long-term roadmap toward disaster response.
Legacy mentions are unverified. A partnership or announcement is not proof of an active deployment. Evidence labels do not change HMX v2 scoring.
Kawasaki KAWARUBA hub
evaluation · vendor-claimed
Demonstrations and pilot test setups at Future Lab HANEDA, KAWARUBA innovation lab
Future Lab HANEDA
evaluation · vendor-claimed
Demonstrations and pilot test setups at Future Lab HANEDA, KAWARUBA innovation lab
Evidence is attached to each value. Robot-wide source links do not verify every field. A source about an older value cannot support the current specification.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
RHP Kaleido 9 is a humanoid robot from Kawasaki Heavy Industries in Japan, and it is at the prototype stage. It scores 46.9 on the Humanoid Metric, ranking 84th of 169.
On the leaderboard it sits between AgiBot Yuanzheng A3 (Expedition A3) (HMX 47.6) and Humanoid HMND 01 (HMX 46.7).
Against the 169 humanoid robots ranked, its clearest strength is manipulation & dexterity (72.5 against a median of 40.0) and its clearest weakness is mobility & locomotion (0.0 against 30.0).
By the published specifications, it is taller than 97% of the 138 other humanoid robots publishing a height (190 cm) and is heavier than 91% of the 125 other humanoid robots publishing a weight (99 kg).
On autonomy, it has demonstrated autonomy under human supervision, not unsupervised work. It has 2 deployments with evidence (2 vendor claimed).
Its specifications carry a medium-confidence grade from 3 cited sources, as of 2026-06.
Task capability is not inferred from hardware specifications or general autonomy labels. Find robots for a task →
No task-specific evidence recorded. Capability remains unknown.
Machine-readable: HIS Layer 0 manifest at /robot/kawasaki-kaleido-9/manifest.json, with a free API key · what's this?
Kawasaki Heavy Industries has not published a price for the Kawasaki Heavy Industries RHP Kaleido 9, and none is estimated here.
Published specifications: payload 18 kg, degrees of freedom 36, height 190 cm, weight 99 kg. Not published: speed, runtime and degrees of freedom per hand.
The Kawasaki Heavy Industries RHP Kaleido 9 has demonstrated autonomy under human supervision, not unsupervised work. The grade reflects demonstrations, not marketing claims.
On the HMX, the Kawasaki Heavy Industries RHP Kaleido 9 scores 46.9 and the AgiBot Yuanzheng A3 (Expedition A3) 47.6. The Kawasaki Heavy Industries RHP Kaleido 9 leads on manipulation & dexterity, hardware & engineering and commercial readiness & deployment; the AgiBot Yuanzheng A3 (Expedition A3) leads on mobility & locomotion and ecosystem & viability.
The Kawasaki Heavy Industries RHP Kaleido 9 is made by Kawasaki Heavy Industries, in Japan.

Nothing is deleted: every version of this record is kept, with what changed in each.