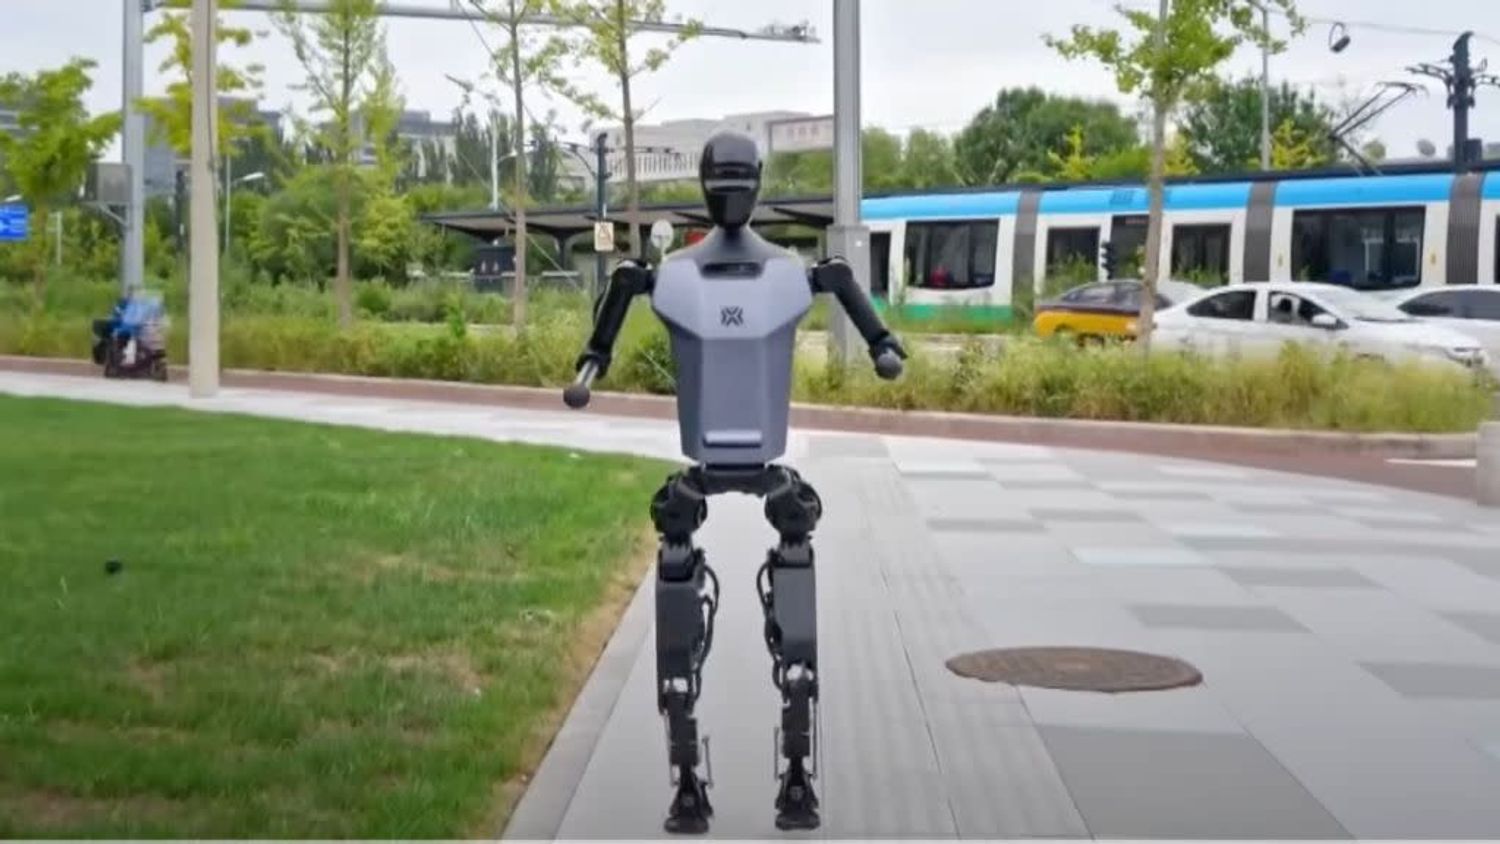
🇨🇳 X-Humanoid Tiangong (Tien Kung)
Watch changes · Evidence history and cited research export (API access) · Plan a pilot
Score breakdown
Each pillar is scored 0–100 from published specs, then weighted into the HMX. Compare it only with other humanoid robots — each category uses its own reference scales. See the full methodology →
Notable
Unveiled April 2024 as the world's first full-size humanoid robot capable of running solely on electric drive, with a steady running pace of 6 km/h (peak ~12 km/h). Released as an open-source mother platform for the Chinese humanoid ecosystem.
Specifications
Evidence is attached to each value. Robot-wide source links do not verify every field. A source about an older value cannot support the current specification.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
unverified · 0 evidence records
Declared shared origins are grouped. Distinct domains and unclassified origins do not establish independent evidence.
No field-specific evidence recorded. This value is unverified at field level.
X-Humanoid Tiangong (Tien Kung) in context: rank, rivals and specs
Compare with SoftBank Robotics / Aldebaran Pepper →Tiangong (Tien Kung) is a humanoid robot from X-Humanoid in China, and it is at the prototype stage. It scores 40.3 on the Humanoid Metric, ranking 114th of 169.
On the leaderboard it sits between SoftBank Robotics / Aldebaran Pepper (HMX 40.9) and KIT High Performance Humanoid Technologies Lab ARMAR-7 (HMX 40.0).
Against the 169 humanoid robots ranked, its clearest strength is mobility & locomotion (66.8 against a median of 30.0) and its clearest weakness is manipulation & dexterity (0.0 against 40.0).
On autonomy, it has demonstrated autonomy under human supervision, not unsupervised work. No deployment is on record.
Its specifications carry a high-confidence grade from 3 cited sources, as of 2026-06.
Task evidence
Task capability is not inferred from hardware specifications or general autonomy labels. Find robots for a task →
No task-specific evidence recorded. Capability remains unknown.
Sources · robot-level references, as of 2026-06
- https://www.globaltimes.cn/page/202404/1311378.shtml
- https://humanoid.press/database/humanoids-tiangong-electric-running-robot/
- https://www.maginative.com/article/meet-tiangong-chinas-full-size-electric-running-humanoid-robot/
Machine-readable: HIS Layer 0 manifest at /robot/x-humanoid-tiangong/manifest.json, with a free API key · what's this?
Frequently asked questions about the X-Humanoid Tiangong (Tien Kung)
How much does the X-Humanoid Tiangong (Tien Kung) cost?
X-Humanoid has not published a price for the X-Humanoid Tiangong (Tien Kung), and none is estimated here.
What are the X-Humanoid Tiangong (Tien Kung)'s specs?
Published specifications: speed 1.67 m/s, height 163 cm, weight 43 kg. Not published: payload, runtime, degrees of freedom and degrees of freedom per hand.
Is the X-Humanoid Tiangong (Tien Kung) autonomous?
The X-Humanoid Tiangong (Tien Kung) has demonstrated autonomy under human supervision, not unsupervised work. The grade reflects demonstrations, not marketing claims.
How does the X-Humanoid Tiangong (Tien Kung) compare to the SoftBank Robotics / Aldebaran Pepper?
On the HMX, the X-Humanoid Tiangong (Tien Kung) scores 40.3 and the SoftBank Robotics / Aldebaran Pepper 40.9. The X-Humanoid Tiangong (Tien Kung) leads on mobility & locomotion and hardware & engineering; the SoftBank Robotics / Aldebaran Pepper leads on manipulation & dexterity, commercial readiness & deployment and ecosystem & viability.
Who makes the X-Humanoid Tiangong (Tien Kung)?
The X-Humanoid Tiangong (Tien Kung) is made by X-Humanoid, in China.
Embed this score

Version history · 2 versions
Full history →Nothing is deleted: every version of this record is kept, with what changed in each.
-
Version 243 · 15 Sep 2026, 04:28 UTC · score then 40.3No field changed; the score was recalculated.Changed by a direct correction or a scoring update, not a research proposal.
-
First recorded version · 6 Sep 2026, 05:24 UTC · score then 40.3The record as it stood when full copies began to be kept.